Daeho Lee
Researcher, Agency for Defense Development (ADD)Daejeon, South Korea
My research background is in sensing, control integration, and experimental evaluation of wearable robots.
At KAIST’s Exo Lab, I worked with Prof. Kyoungchul Kong on sensor development and experimental evaluation of powered exoskeletons. My contributions included distance- and force‑sensing hardware, a distance-based swing-control layer, and walking experiments. I received my B.S. (2020) and M.S. (2022) in mechanical engineering from KAIST.
At ADD, my work includes integrated product support and defense standardization, engineering-system development management, and CATIA automation for CAD data transfer. Professional experience
CV · October 2026 · 2 pages. Google Scholar
Research interests
Wearable and legged robots
- Physical human–robot interaction
- coupled dynamics, compliance, and physical interfaces.
- Perception-guided assistive control
- intent inference amid reactive responses, and pre-contact sensing.
- Biomechanical evaluation
- interaction loads, locomotor performance, and human adaptation.
Research
Selected projects in sensing, assistive-control integration, and experimental evaluation.
 01 · Sensing and control
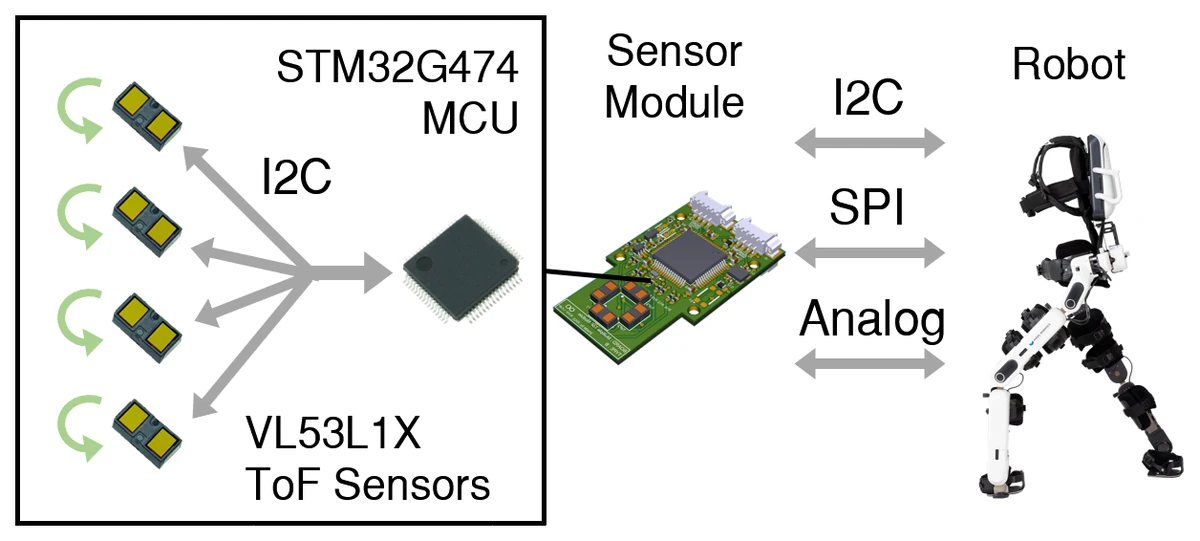
Foot–ground distance sensing
Foot–ground ranging for gait-phase detection and distance-based swing control before initial contact.
J5T1M1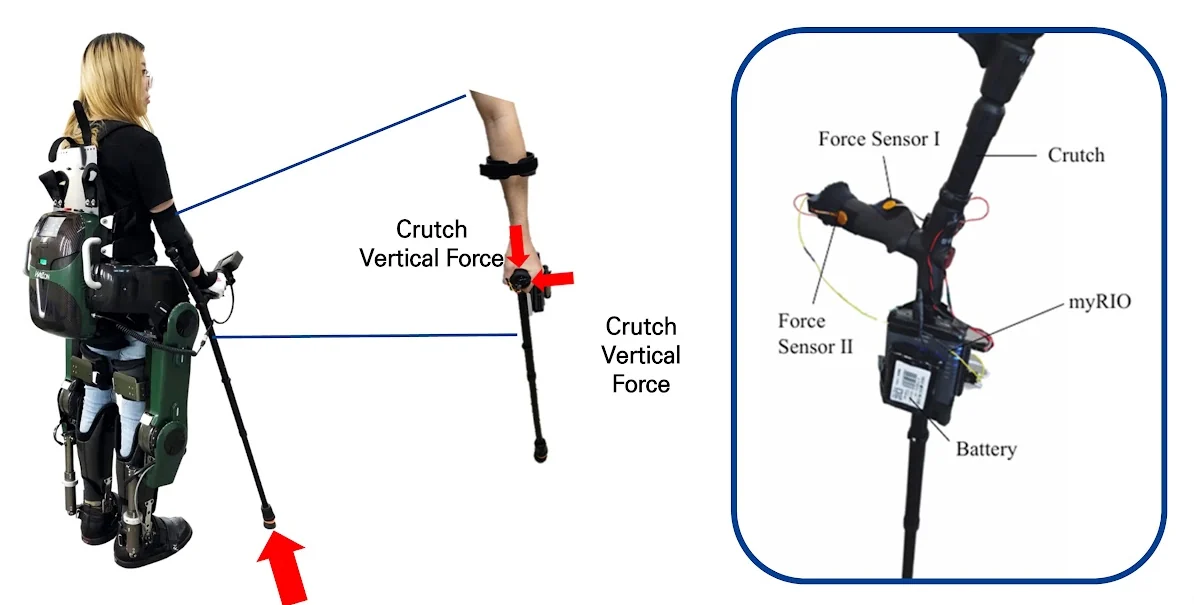 02 · Experiments
Exoskeleton instrumentation
Plantar-pressure and crutch‑force modules, and the shock‑absorption experiments on a modified WalkON Suit 4.
J4C1J1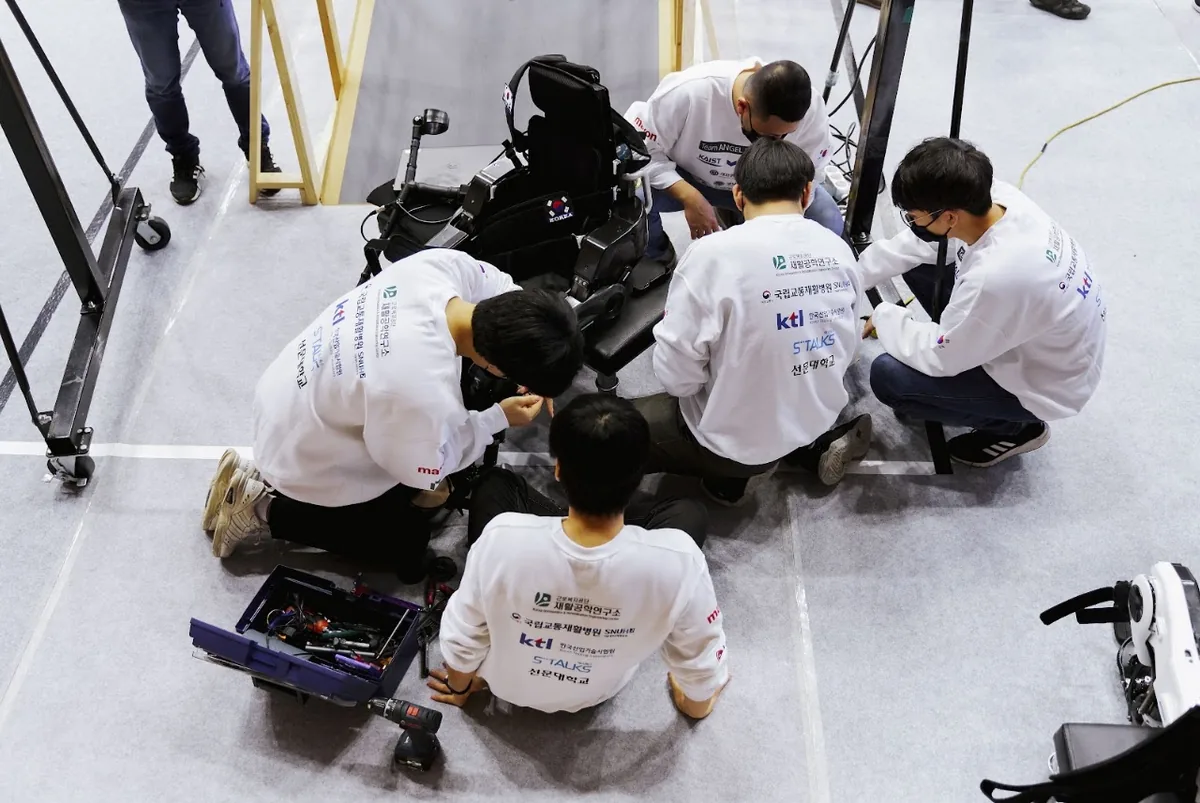 03 · Integration
WalkON Suit and CYBATHLON 2020
Assembly and debugging of the team’s WalkON Suit IV exoskeletons. Team gold and bronze medals.
J3Timeline
- 2026Journal article on real‑time gait‑phase detection with non‑contact distance sensors, published in JKSPE.
- 2024Certificate of Commendation, Chief of Staff, Republic of Korea Army.
- 2023Joined ADD as a researcher in April. Journal article on the shank shock‑absorption mechanism published in IJCAS.
- 2022M.S., KAIST. Thesis on foot–ground distance sensing and a distance-based swing-control layer, tested on Angel Legs M20.
- 2021ICRA 2021 paper on reducing the ground impact of a powered exoskeleton. ASME ISPS 2021 presentation on gait‑phase detection with sensor‑integrated shoes. KAIST Global Leadership Award, Challenge Division, shared with two CYBATHLON teammates.
- 2020CYBATHLON 2020: team gold and bronze medals in the Powered Exoskeleton Race. Led a KAIST Venture Research Program project. B.S., KAIST, magna cum laude; began the M.S. on a full‑tuition KAIST scholarship.
- 2013–20Undergraduate study at KAIST on full‑tuition scholarships: KAIST (2013–2014) and the National Excellence Scholarship for Science and Engineering, Ministry of Education (2015–2019). Military service as a KATUSA at AFN Korea, 2016–2018.