Research

Sensing, assistive-control integration, and biomechanical evaluation.

These research projects originated in my graduate and post‑master’s research at KAIST’s Exo Lab (2020–2023). Click a figure to enlarge it.

Research interests

Wearable and legged robots

Physical human–robot interaction
coupled dynamics, compliance, and physical interfaces.
Perception-guided assistive control
intent inference amid reactive responses, and pre-contact sensing.
Biomechanical evaluation
interaction loads, locomotor performance, and human adaptation.

01

Foot⁠–⁠ground distance sensing

Time‑of‑flight (ToF) sensors measure foot⁠–⁠ground distance during walking. The distance signal remains available during swing, complementing pressure‑based measurements during stance.

Real‑time gait‑phase detection

What I did

Designed a shoe‑mounted module with two ToF sensors, near the lateral heel and the fifth metatarsophalangeal (MTP) joint, and a threshold‑based algorithm that segments the gait cycle into six phases in real time. This work was presented at ASME ISPS 2021 [T1] and subsequently reported in JKSPE [J5].

Evaluation

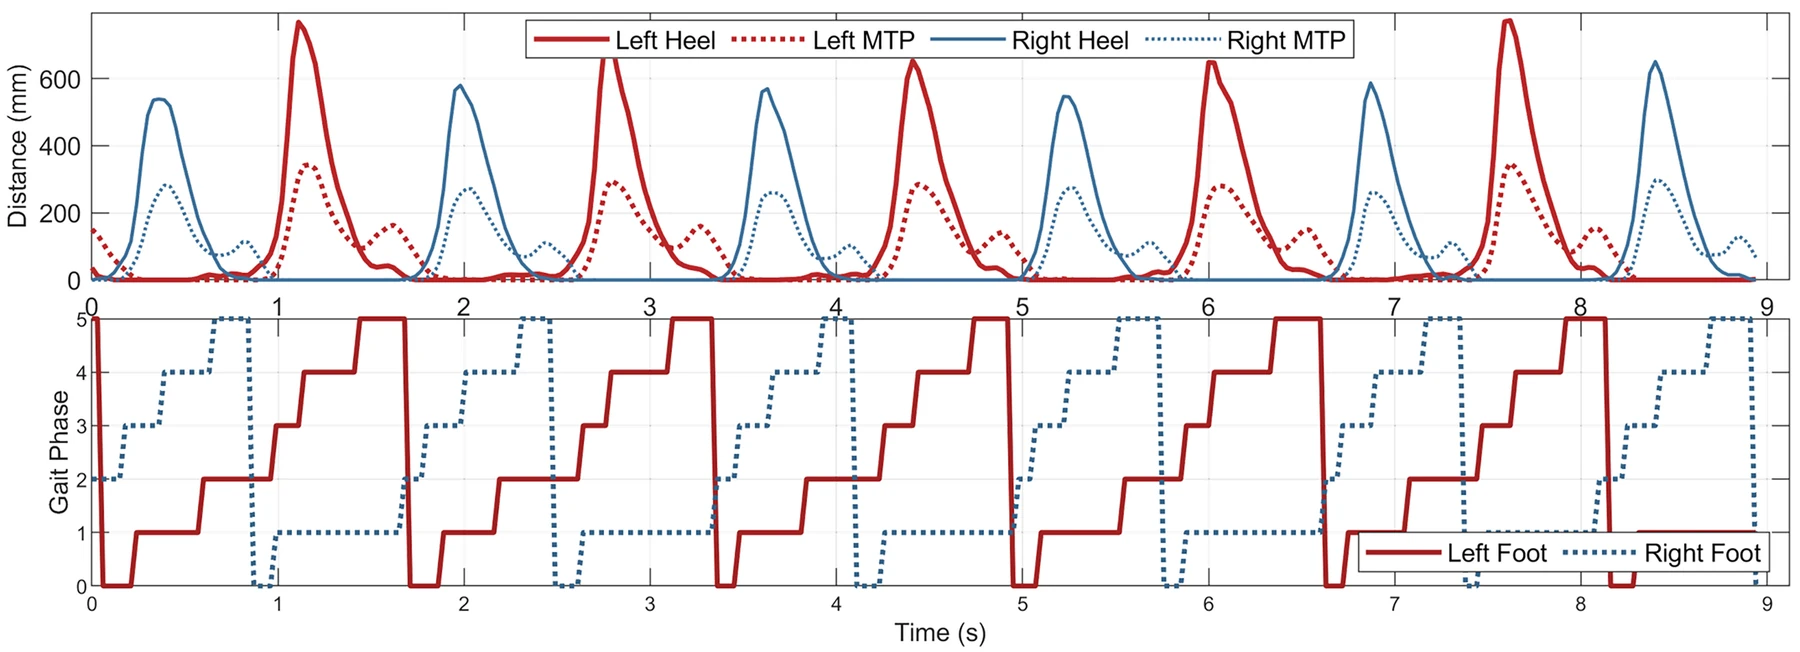
One healthy participant walked on a flat indoor floor, with about 20 full gait cycles per trial set [J5]. Compared with air‑bladder pressure measurements, the distance‑based method reported swing fractions 3.6 and 5.9 percentage points lower for the left and right foot, respectively (Table 2). It also provided distance measurements during swing [J5].

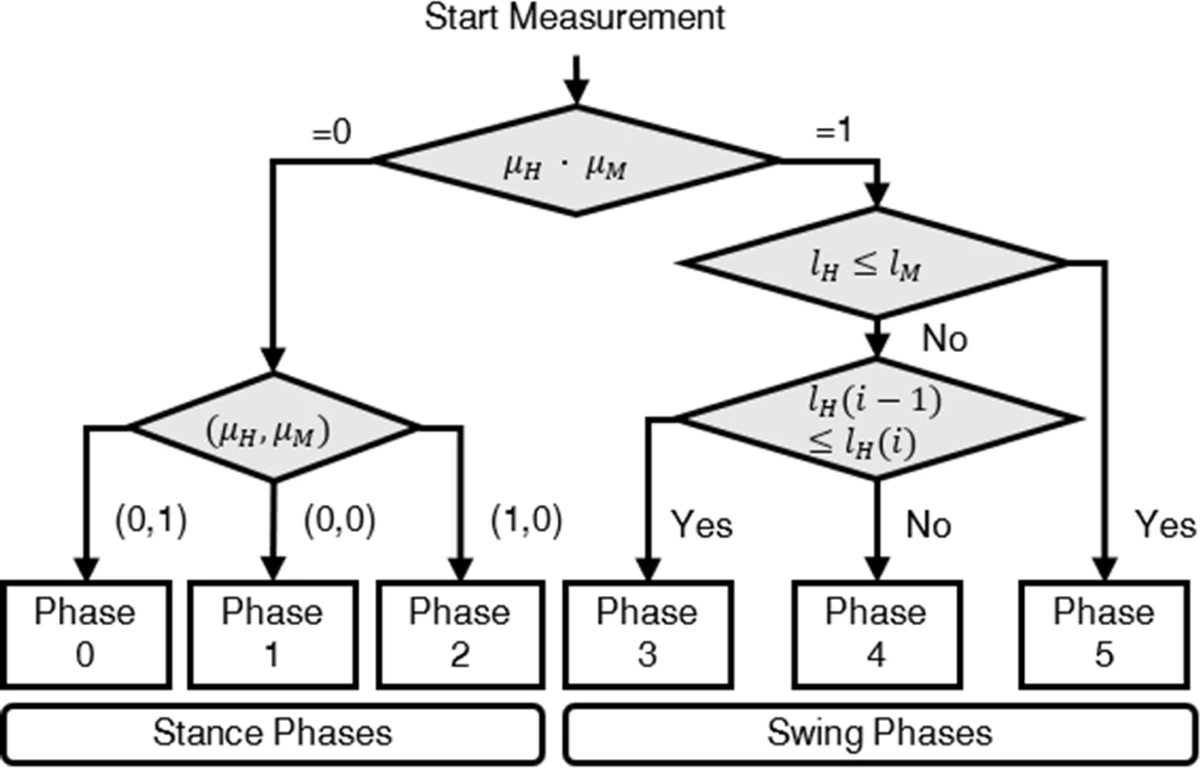
Design choices. The algorithm defines six gait states from heel and forefoot contact flags, the relative sensor distances, and whether the heel distance is increasing or decreasing. After subtracting the standing offset from each distance signal, small thresholds were used for contact-state detection rather than precise near-ground ranging. During swing, successive heel readings were compared without explicitly estimating velocity [J5, Sections 3.2 and 4.2].
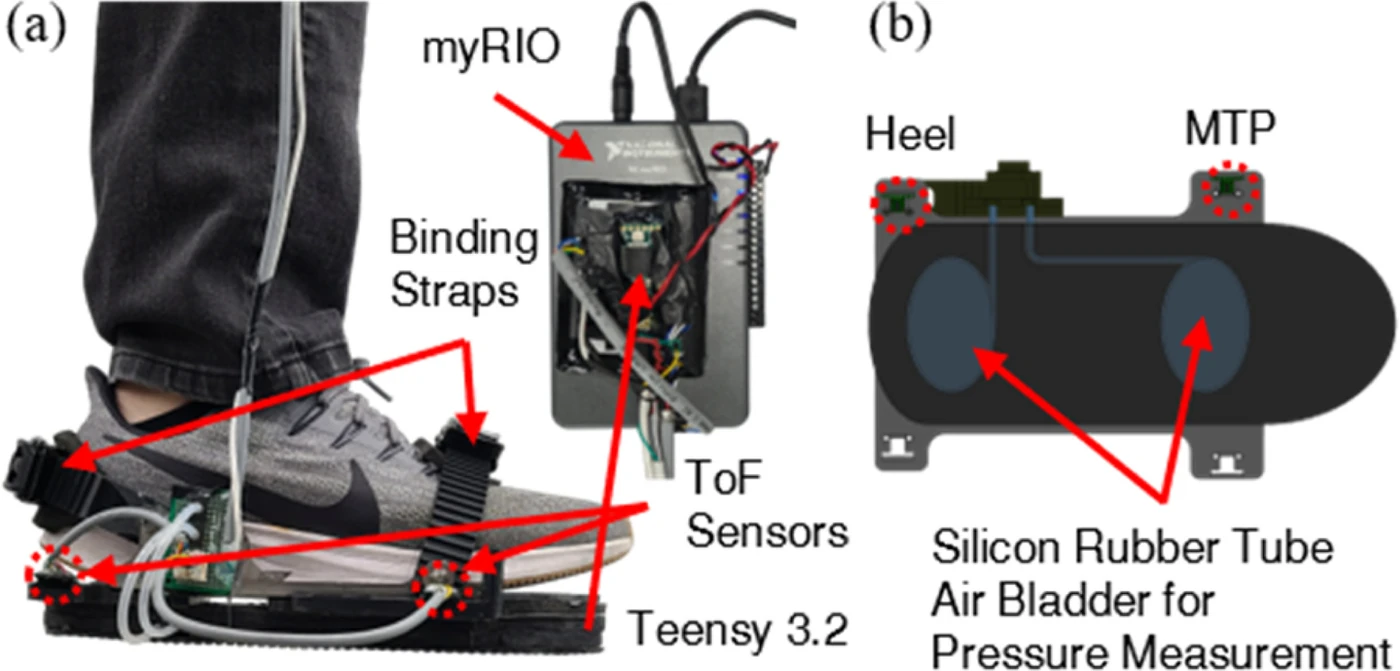
Two photographs: the sensor module strapped under a sneaker with two ToF sensors, a Teensy 3.2 board and a myRIO controller; and the bottom view with silicone-tube air bladders at the heel and MTP
(a) Shoe‑mounted module with two ToF sensors, a Teensy 3.2 board and a myRIO controller; (b) bottom view with the silicone‑tube air bladders used as the pressure reference [J5, Fig. 2].
Flowchart: contact flags from the heel and MTP thresholds select phases 0 to 2; in swing, comparisons of heel and MTP distances and of successive heel readings select phases 3 to 5
Decision logic: contact flags separate the stance phases 0–2; in swing, the heel–MTP relation and the change in heel distance separate phases 3–5 [J5, Fig. 8].
Two stacked plots over nine seconds of walking: heel and MTP distances for both feet, and the detected gait phase for each foot
Distances (top) and detected phases (bottom) for both feet during continuous walking [J5, Fig. 10].

Figures 2, 8, and 10 from D. Lee, “Real-time Gait Phase Detection System Using Non-contact Distance Sensors”, JKSPE (2026). © Korean Society for Precision Engineering. CC BY‑NC 3.0; converted to WebP for display.

Pre-contact sensing for initial-contact load modulation

What I did

Designed the circuit and wrote the software for a foot⁠–⁠ground distance module (four ToF sensors, STM32 microcontroller). A labmate laid out the PCB from that circuit; I assembled and tested the boards and integrated the module into the Angel Legs M20 exoskeleton. I implemented a distance-based swing-control layer on the exoskeleton and ran treadmill walking experiments over tandem force plates with the layer off and at two settings. This was my M.S. thesis, Terminal Decision Maker Against Upcoming Surface for the Safe Locomotion of Wearable Robots.

Pilot result and status

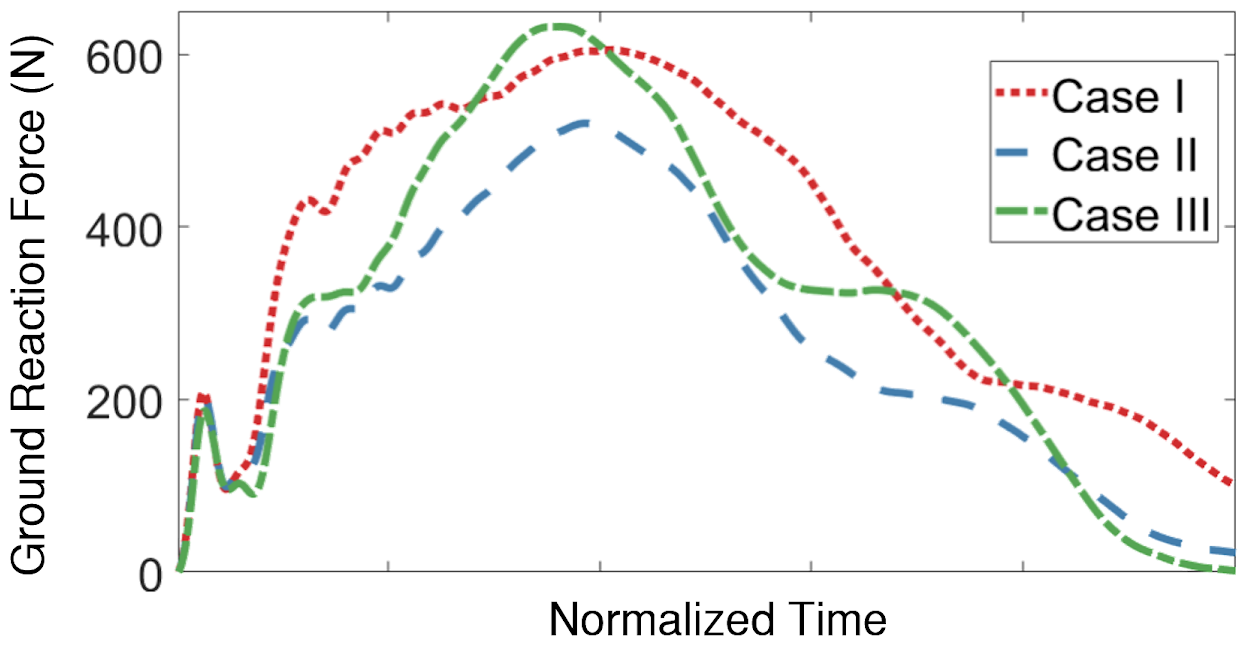
A single-participant treadmill pilot showed 24.7%–28.9% lower vertical impulse on the anterior force plate over the first 100 ms after force onset than with the layer off [M1].

A manuscript, FDL: Foot⁠–⁠Ground Distance Layer for Initial‑Contact Load Modulation in a Lower‑Limb Exoskeleton, is in preparation [M1]. It builds on the thesis experiments.
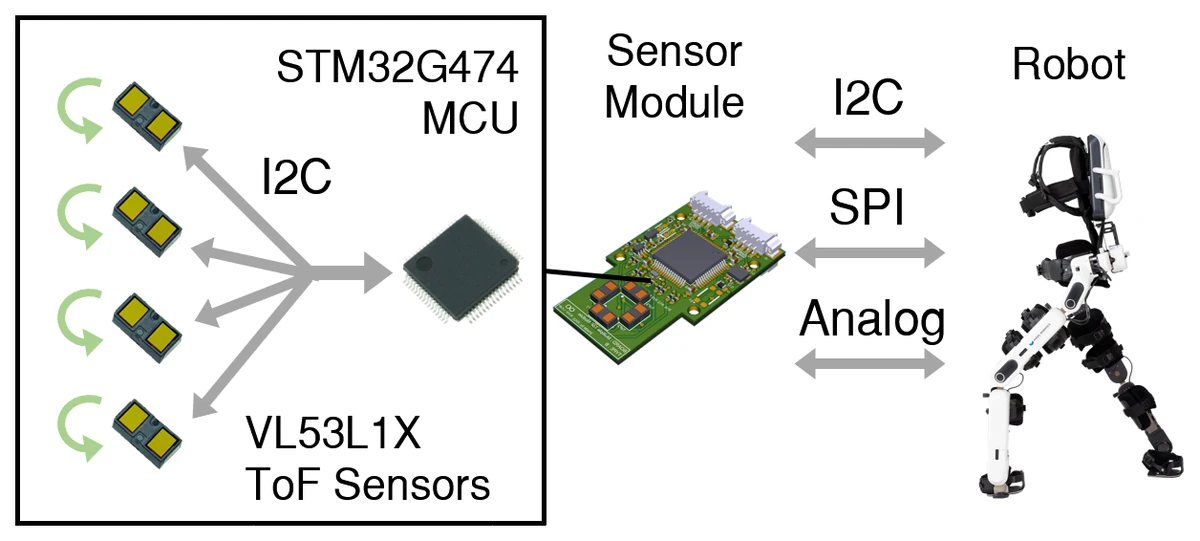
Block diagram of the sensor module: four VL53L1X time-of-flight sensors on an I2C bus, an STM32G474 microcontroller, and SPI and analog outputs to the robot
Module architecture: four VL53L1X ToF sensors over I²C, an STM32G474 microcontroller, SPI and analog outputs to the robot.
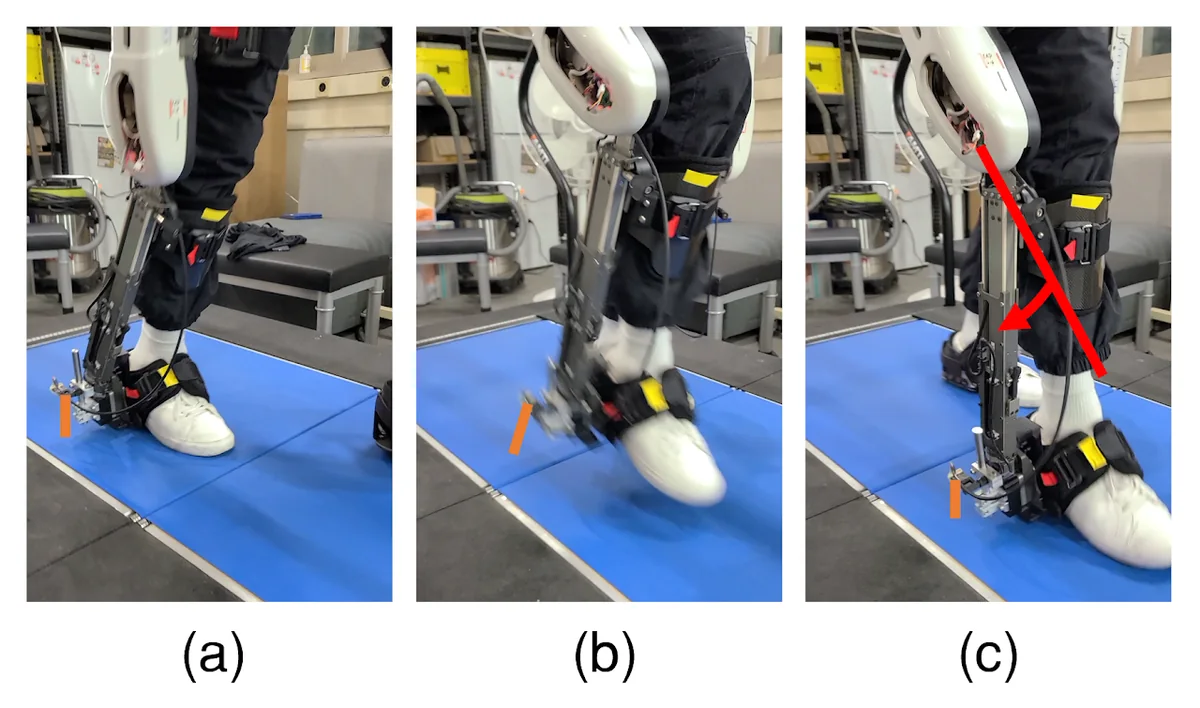
Three photographs of the distance module mounted on the foot of the Angel Legs M20 exoskeleton during walking trials
The module on the foot of the Angel Legs M20 during walking trials.
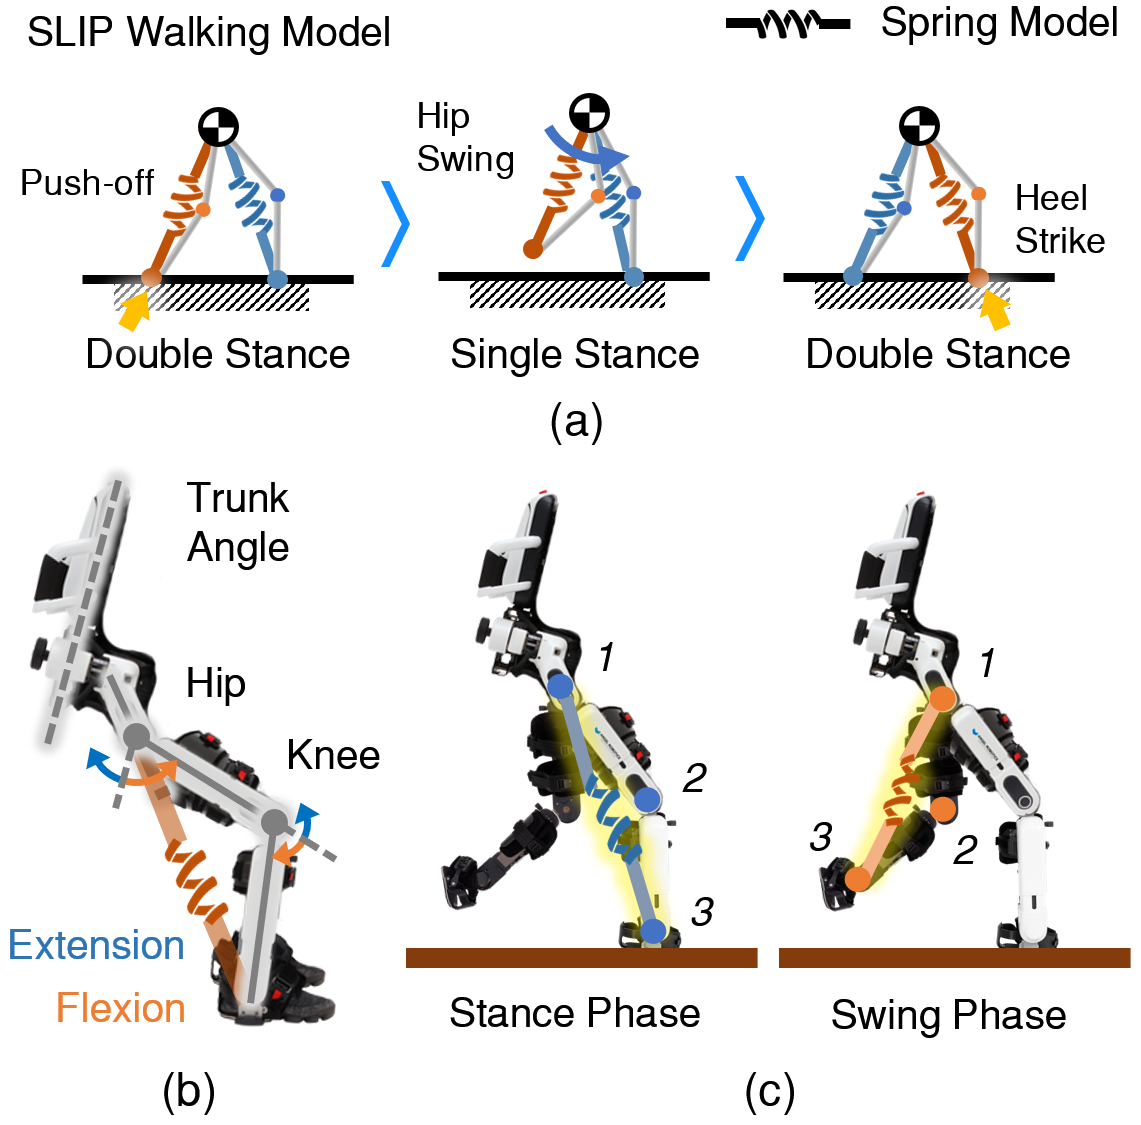
Thesis diagram showing a walking model, joint flexion and extension, and stance and swing configurations
Thesis concept diagram: (a) walking model; (b) joint flexion and extension; (c) stance and swing configurations.
Plot of vertical ground-reaction force in newtons over normalized time for three conditions labelled Case I, II and III
Vertical ground‑reaction force through one stance phase (time‑normalized) for the three thesis conditions: virtual‑spring pre‑tuning off (Case I), weak (Case II) and strong (Case III). The manuscript in preparation calls these FDL off, weak and strong. This thesis illustration shows the stance phase; the quantitative pilot comparison above uses only the first 100 ms of anterior-plate loading.

02

Exoskeleton instrumentation and shock‑absorption experiments

Measuring foot⁠–⁠ground and hand–crutch forces during exoskeleton walking, to evaluate a shock‑absorption mechanism on the shank.

What I did

Developed an FSR-based crutch‑force module, including the choice of sensor placement [J1], and pneumatic plantar‑pressure modules; fabricated components and instrumented a modified WalkON Suit 4, and ran the shock‑absorption experiments [C1, J4].

Reported result

In the journal study, the shock absorber with the designed gait pattern reduced the mean peak heel ground‑reaction force by 23% compared with no absorber, in one participant [J4]. Forces measured on one crutch were also lower (root‑mean‑square: 11% vertical, 26% horizontal), so the lower heel load was not accompanied by higher forces at the instrumented crutch [J4]. The journal article extends the ICRA 2021 study [C1].

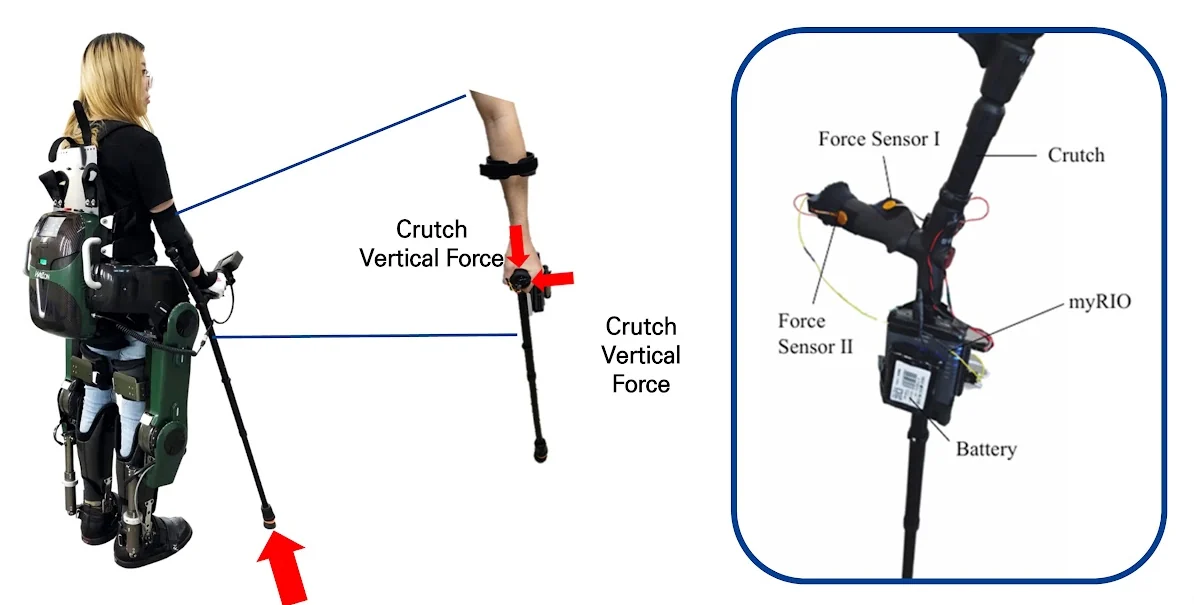
A person wearing the exoskeleton with instrumented crutches, and a close-up of the crutch module with two force sensors, a myRIO controller and a battery
FSR-based crutch‑force module: two force sensors at the grip, with a myRIO controller and battery on the crutch [J1].

03

WalkON Suit and CYBATHLON 2020

Hardware work on the team’s powered exoskeletons for the CYBATHLON 2020 Powered Exoskeleton Race.

What I did

Assembled and debugged the team’s WalkON Suit IV exoskeletons for CYBATHLON 2020.

Team outcome

Gold and bronze medals in the Powered Exoskeleton Race. Three graduate students on the team, including me, received the KAIST Global Leadership Award. The overview article [J3] describes the WalkON Suit system.

CYBATHLON 2020 Global Edition - EXO Finals
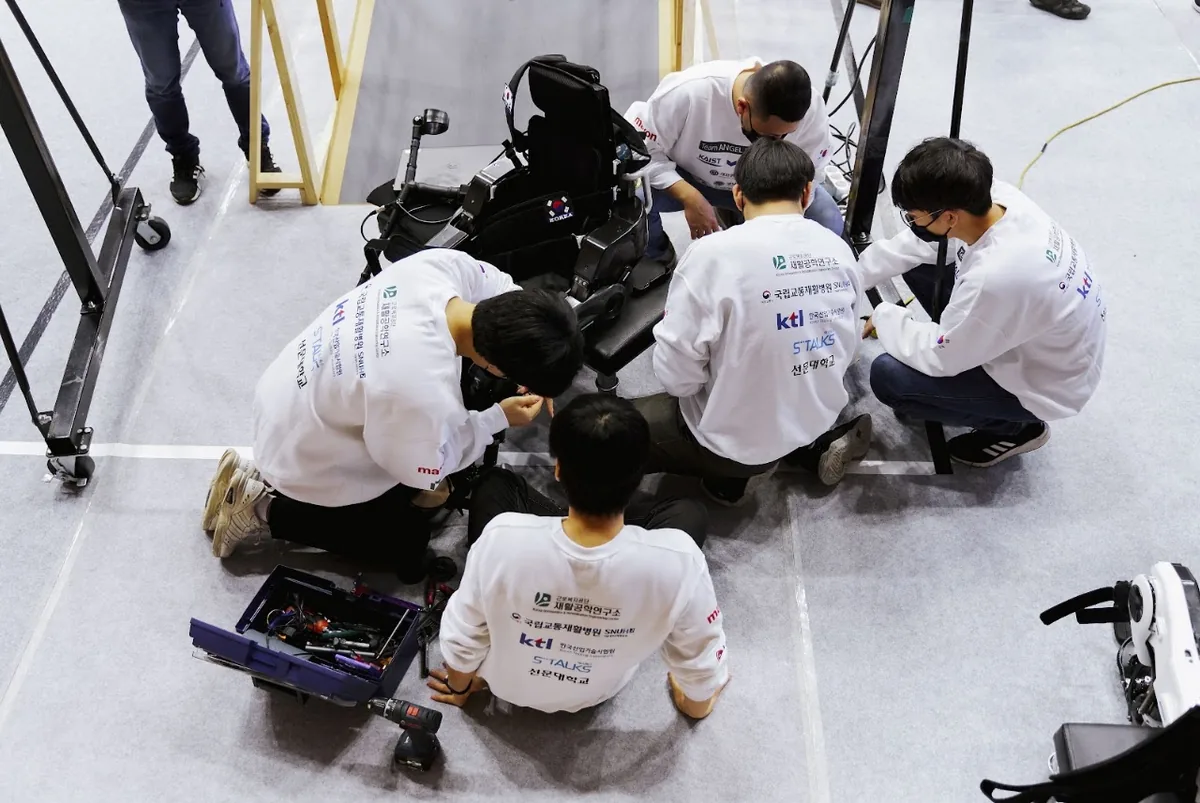
Team members kneeling around the exoskeleton on the floor of the competition hall
Servicing the exoskeleton between runs.
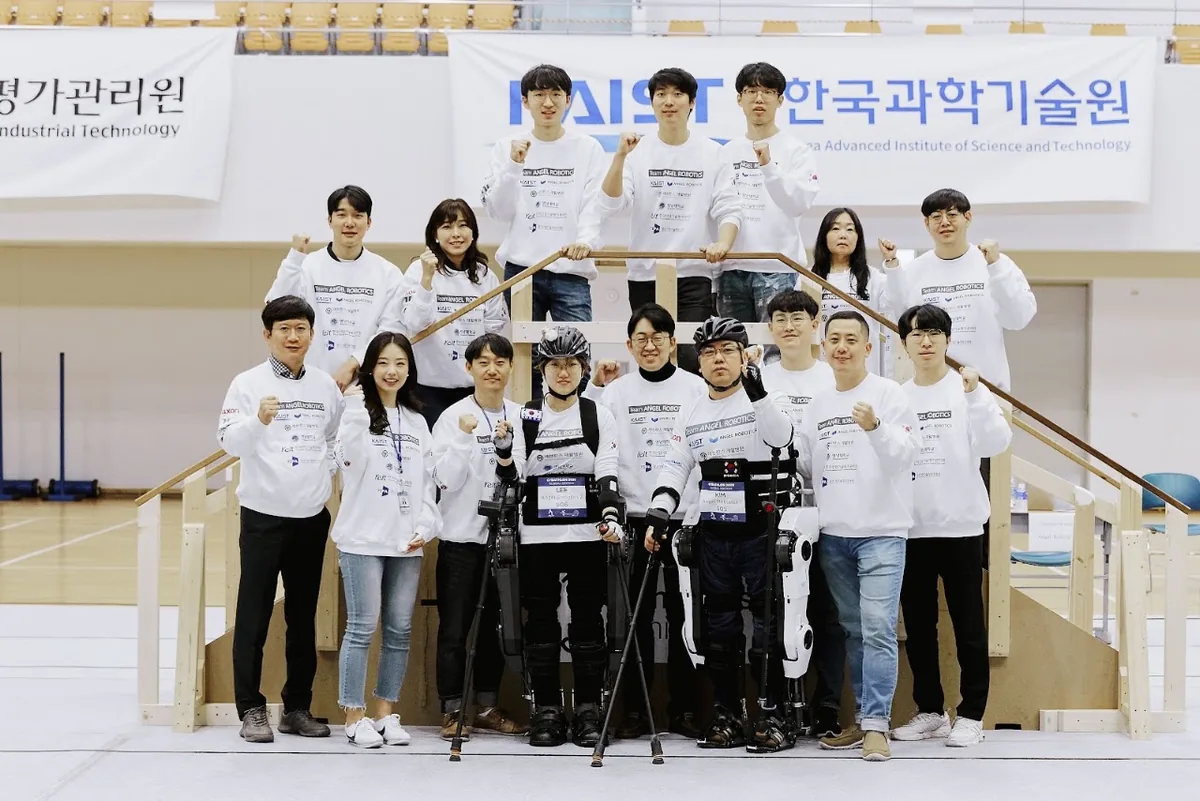
Team photo with the exoskeleton in front of a KAIST banner
The team at its CYBATHLON 2020 venue.

04

Experimental systems for wearable-robot evaluation

Measurement-system integration and analysis software for wearable-robot evaluation.

Instrumentation

Worked with VICON motion capture, an AMTI instrumented treadmill, Delsys EMG, Xsens inertial sensors, and custom sensors for wearable-robot evaluation.

Analysis and modeling

Built OpenSim human–robot models and MATLAB analysis pipelines for motion, force, and surface electromyography (sEMG) data.

05

Student-led project: user- and task-aware exoskeleton dimensions

KAIST Venture Research Program for Graduate Students, 2020. Six months, KRW 20 million (≈US$17,000).

What I did

Formed and led the student team, wrote the proposal, secured the grant, and built a force-sensing data-acquisition system by adapting the instrumentation I had developed.

Collaboration

A collaborating group performed the machine learning on the collected data.

Professional experience

Agency for Defense Development (ADD)

Researcher, 2nd R&D Institute · April 2023–present

  • Co-led integrated product support (IPS) and defense standardization across multiple Republic of Korea Army R&D and production programs (details restricted).
  • Managed development of an extended-reality procedural-training system and a technical-data verification system upgrade.
  • Developed a CATIA automation tool for secure CAD data transfer across air-gapped networks.